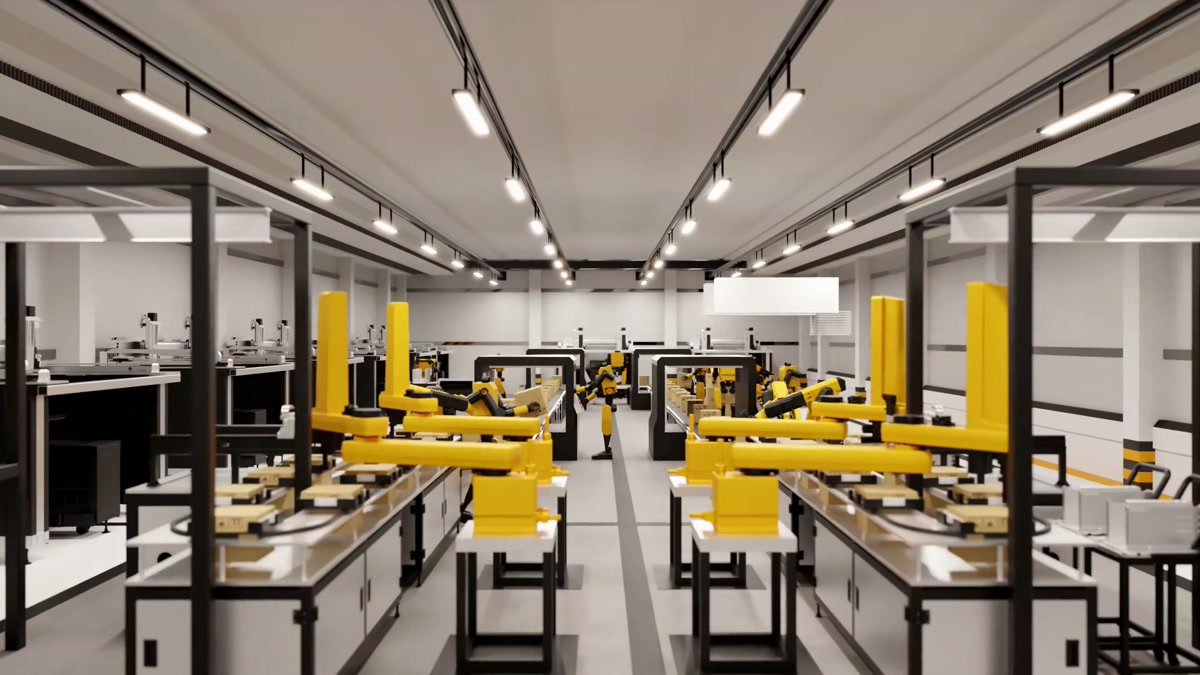
Robot Industrial Animation
Confidential
[ 01 ] — The brief
The client — a robotics company working through a capital raise — needed a film demonstrating their collaborative robotic arm across multiple use cases without access to a production-ready prototype. The hardware was still in late-stage development. The film needed to show the robot performing three distinct tasks with the physical plausibility of a system that actually exists, for an audience of investors who would know the difference.
[ 02 ] — The approach
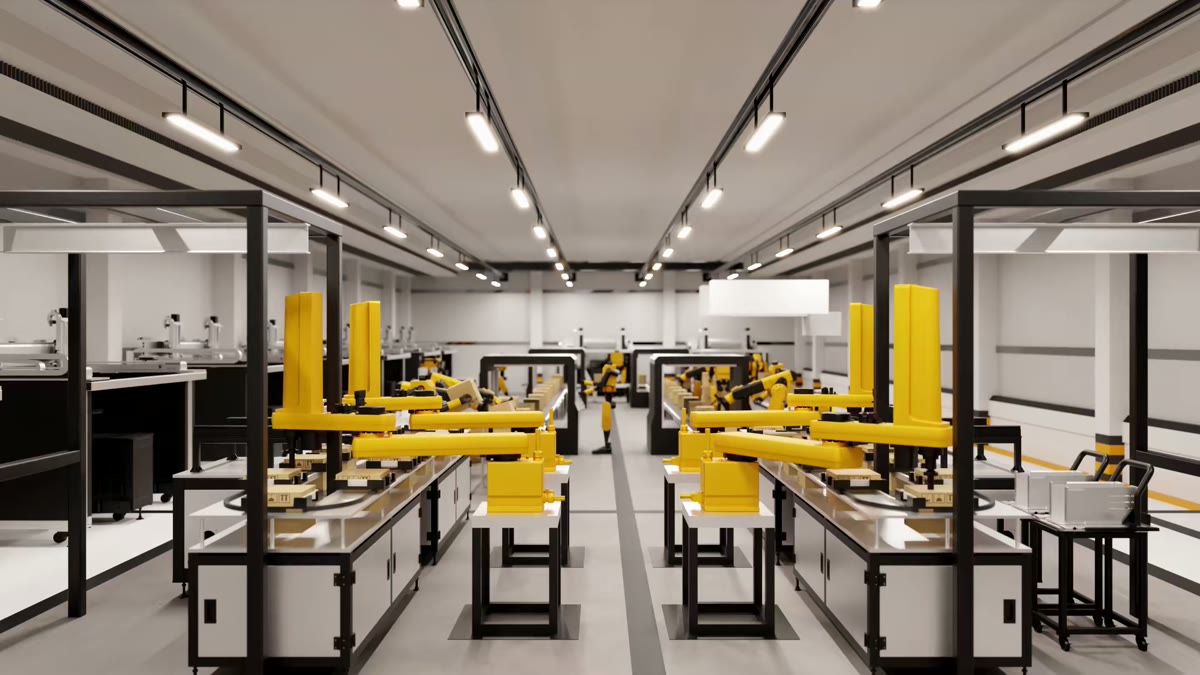
We built the robot geometry from mechanical specification documents only, with no physical reference. Inverse kinematics were implemented in Houdini and tuned against the specified joint ranges and payload ratings, ensuring every motion path shown in the film was within the system's actual operating envelope. The environment — a light-industrial assembly cell — was designed to feel architecturally considered rather than photorealistic, keeping the robot as the unambiguous visual subject throughout.
[ 03 ] — The result
The film was used in the client's fundraising materials and delivered within the timeline required for the raise. At the client's request we do not identify them publicly — but the round closed.
[ 04 ] — Gallery